
ENGINEERING PROJECT · P0
SAMO Rehabilitation Robot
Safety-Oriented Active Elbow Rehabilitation Robot
A one-degree-of-freedom concept for controlled elbow flexion and extension. The project brings together rehabilitation requirements, electromechanical architecture, motion-control concepts and safety planning.
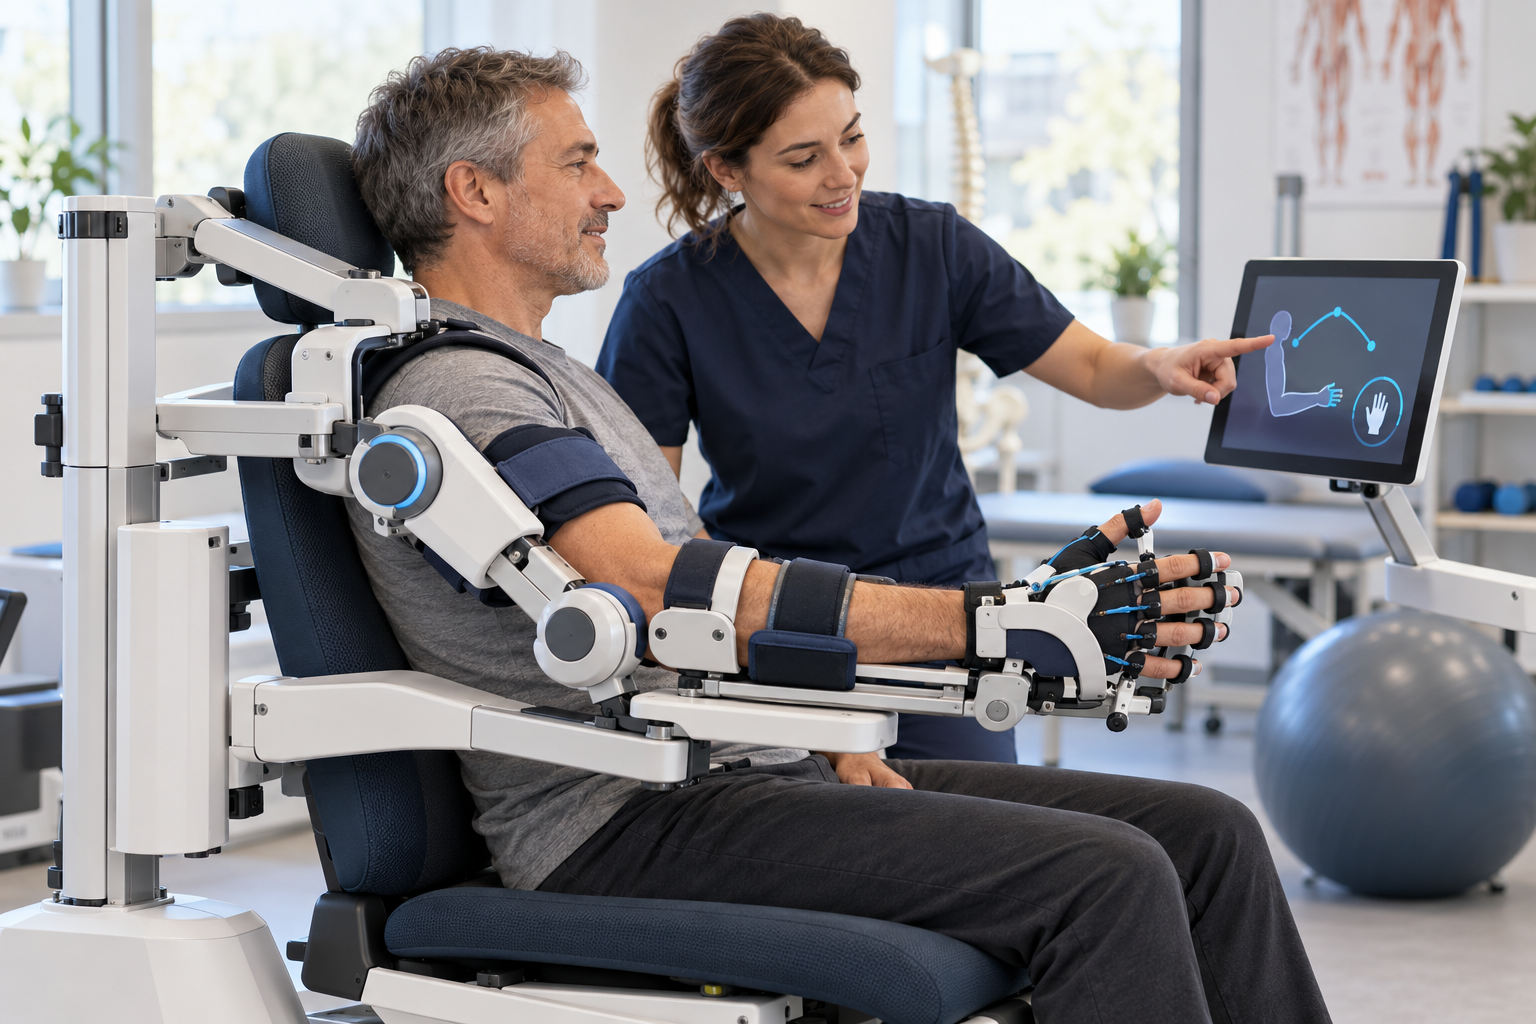
From rehabilitation needs to an engineering concept.
SAMO P0 explores a modular elbow-rehabilitation robot concept, with adjustable upper-arm and forearm supports and a proposed electromechanical architecture. Candidate rehabilitation modes were considered at the concept level; they are not implemented or validated device capabilities.
- BLDC actuation with a proposed reduction transmission.
- Concepts for position and interaction force/torque sensing.
- Motion-control architecture with range-of-motion constraints.
- Safety concepts including mechanical limits, an emergency-stop pathway, fault handling, diagnostics and session logging.
Earlier concept and assessment work also explored shoulder and hand/finger rehabilitation. The engineering dossier documented on this page covers SAMO P0’s elbow concept only; design parameters are not patient-safe operating limits, and no shoulder or hand/finger mechanism is claimed as a completed SAMO P0 design.
Engineering work in progress; physical verification remains open.
This page documents ongoing engineering work, not a finished medical device. Component selection, physical integration and bench verification remain open. No human-use testing, clinical evaluation, regulatory assessment or certification is represented. The concept must not be used to guide treatment or rehabilitation. Any future physical prototype would require appropriate engineering verification, risk management and regulatory review before any intended clinical use.
For project enquiries, email Samuel Motlagh. Please do not send health or other sensitive information.
← Back to SAMO CyberShield